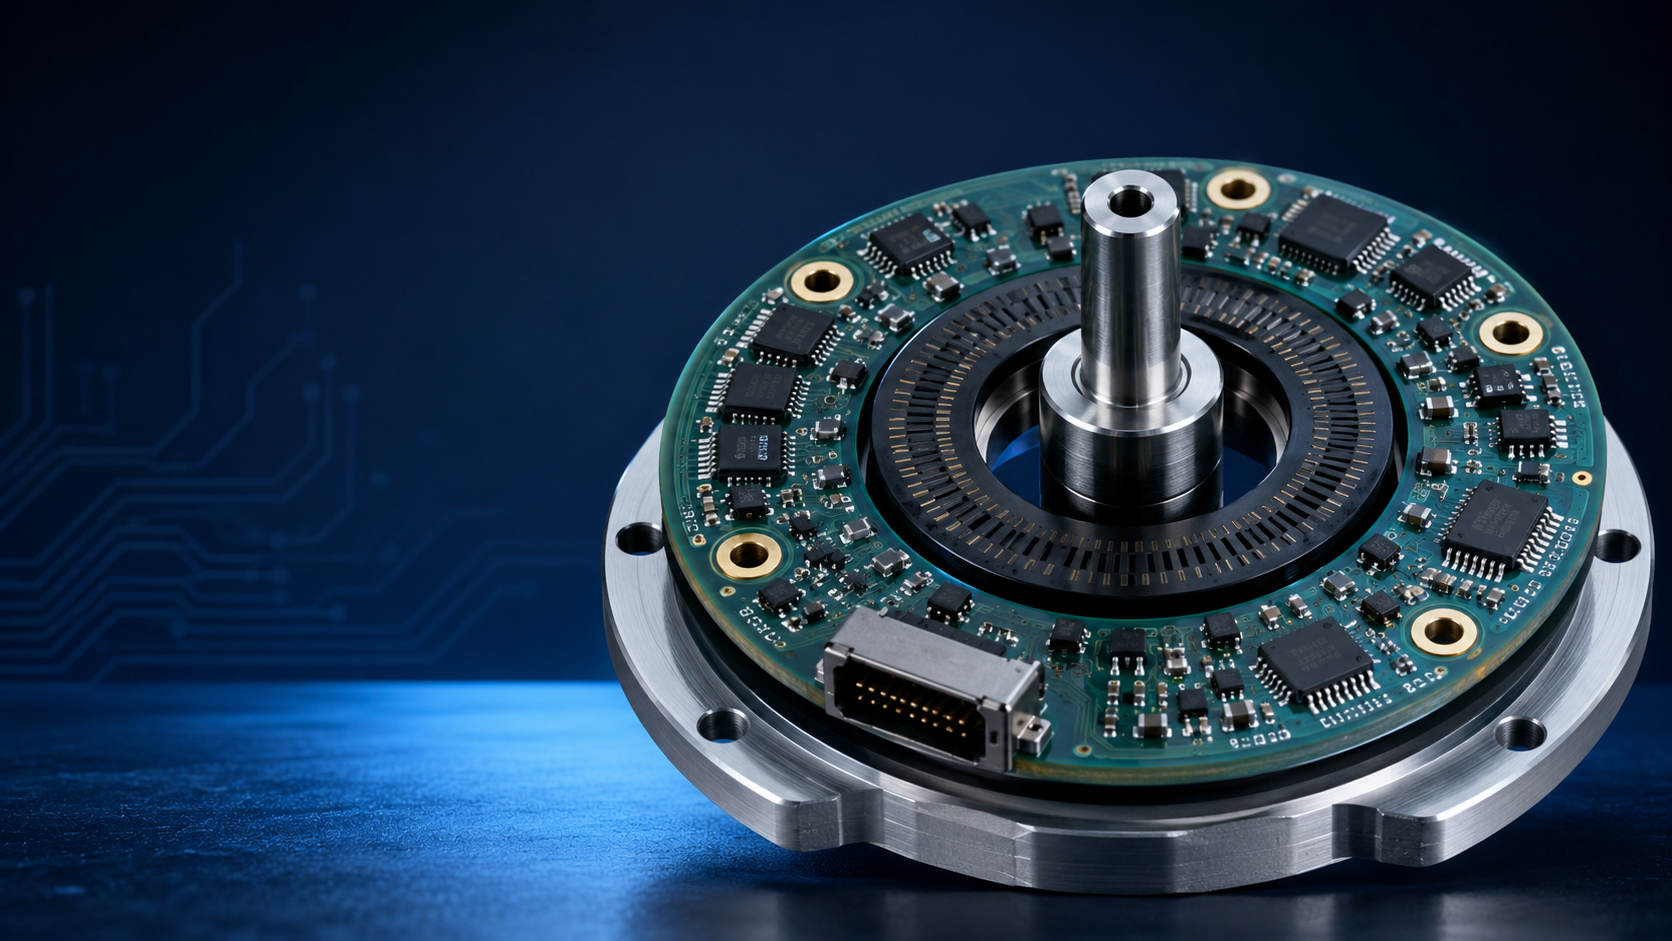
Key Features
Incremental or absolute position output
Compact circular mechanical formats
High-resolution feedback
Temperature and alignment compensation
Typical Electronic Components
Encoder sensor IC or optical receiver; magnet/LED interface; MCU; EEPROM; differential line driver; regulator; connector.
Reference PCB and PCBA Parameters
Reference item | Typical guidance |
Typical layers | 2-6 layers |
Board shape | Circular, annular or custom outline |
Interfaces | ABI, SSI, BiSS-C, SPI, PWM or proprietary |
Tolerance focus | Sensor-to-target alignment and board concentricity |
Finish | Selected for connector and assembly needs |
Testing | Angle sweep, linearity, repeatability and communication |
Manufacturing and Engineering Priorities
Control sensor air gap, concentricity and magnet/scale alignment.
Keep switching nodes and motor phase currents away from the sensing area.
Use stable references and low-noise regulation.
Calibrate complete assemblies when the sensor technology requires it.
Design and Commercial Cautions
Resolution is not the same as absolute accuracy. Mechanical eccentricity can dominate electronic error. Define operating temperature, speed and allowable latency.
|
Applications
Servo motors, robot joints, wheels, grippers and precision axes.

