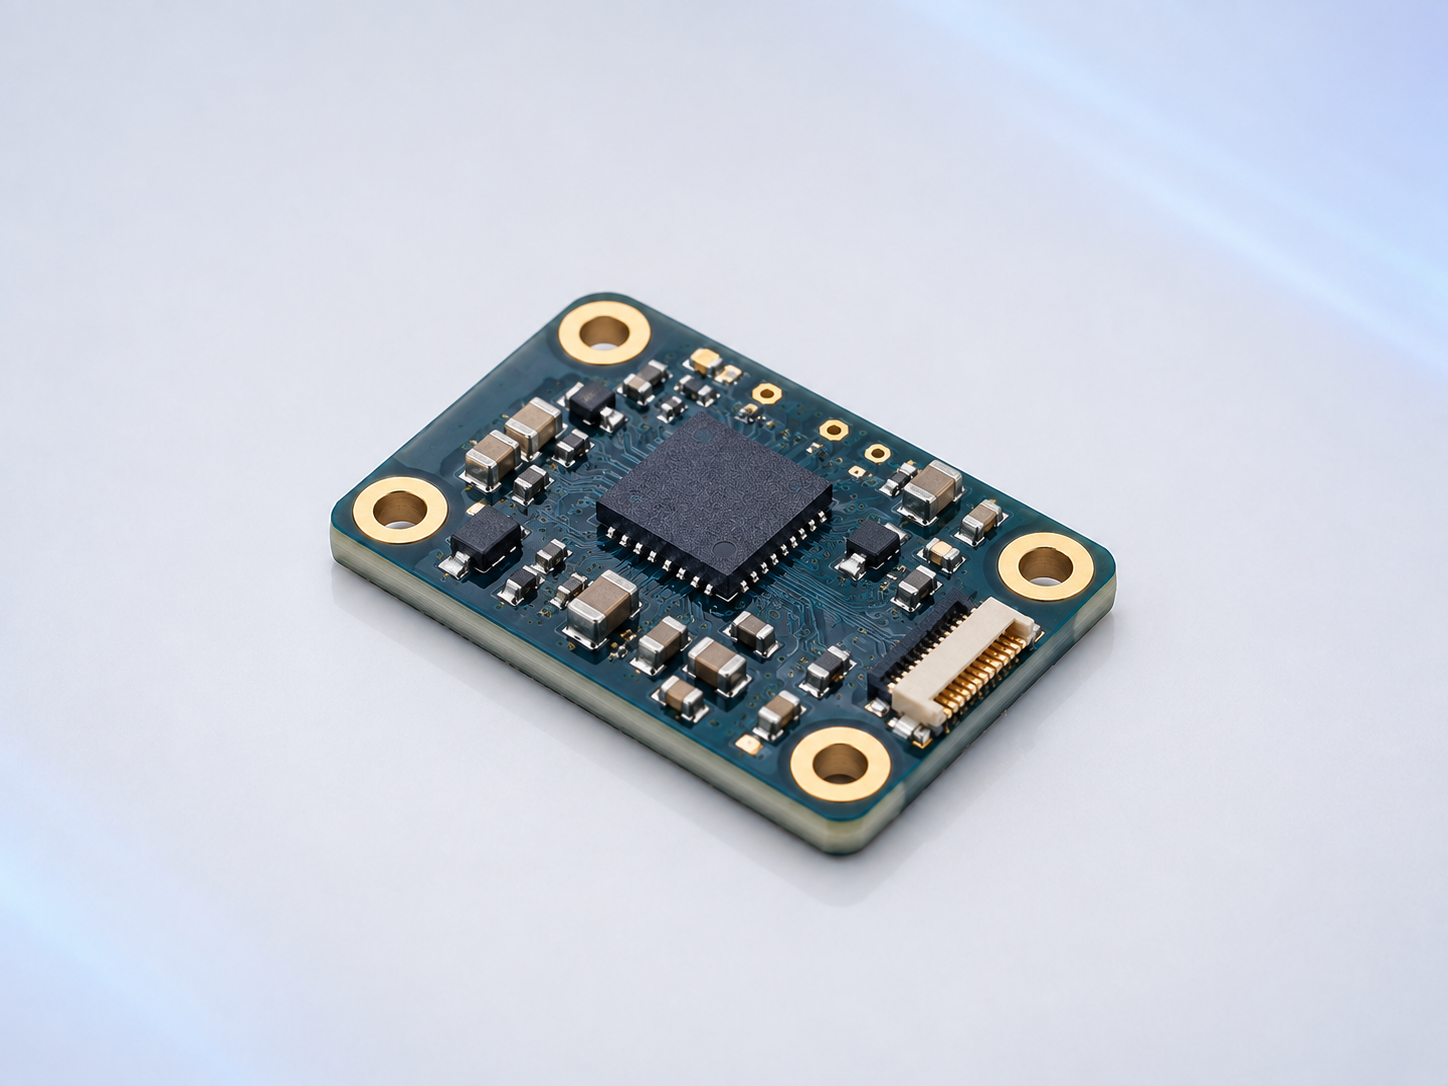
The gyroscope sensor module is designed to measure theangular velocity and rotational movement of robotic systems. It detectsrotation around the roll, pitch and yaw axes, providing real-time motion datato the robot’s control system.
Using compact MEMS sensing technology, the module supportsfast response, stable performance and easy integration into space-constrainedrobotic platforms. Gyroscope data can be combined with accelerometers, encodersand other sensors to improve attitude estimation, motion control and navigationaccuracy.
The module is suitable for humanoid robots, robot dogs,robotic arms, AGVs, AMRs, drones and autonomous inspection equipment. Differentsensing ranges, communication interfaces and PCB configurations can becustomized according to specific project requirements.
Key Applications
Angular velocity measurement
Roll, pitch and yaw detection
Robot balance and posture stabilization
Rotational motion tracking
Robotic joint movement monitoring
Navigation and attitude estimation
Vibration and abnormal-motion detection
Multi-sensor data fusion
Main Advantages
Compact MEMS sensor design
Fast rotational-motion response
Stable and reliable measurements
Suitable for dynamic robotic applications
Easy integration with robot control systems
Customizable PCB and interface options
Main Components of the Gyroscope Module
Component | Function |
MEMS Gyroscope Sensor | Measures angular velocity around one or more rotational axes. A three-axis gyroscope detects rotation around the roll, pitch and yaw axes. |
Sensor ASIC | Drives the MEMS sensing structure, processes the original signal and converts mechanical movement into usable electrical data. It is usually integrated with the MEMS sensor. |
Analog-to-Digital Converter | Converts the analog sensing signal into digital angular-velocity data. It may be integrated into the gyroscope IC. |
Signal-Conditioning Circuit | Amplifies and filters the sensor signal to improve stability and reduce electrical noise. |
Temperature Sensor | Measures the internal temperature and supports compensation for temperature-related bias and sensitivity changes. |
MCU or Processing IC—Optional | Performs calibration, digital filtering, fault detection and communication management. |
Voltage Regulator | Provides a stable operating voltage for the sensor and processing circuits. |
Crystal or Oscillator | Supplies an accurate timing reference for sampling, filtering and communication. It may be integrated into the sensor IC. |
Flash Memory or EEPROM—Optional | Stores calibration coefficients, configuration settings and temperature-compensation data. |
Interface or Level-Shifting Circuit | Connects the module to the robot controller and matches different communication-voltage levels. |
ESD and Input-Protection Components | Protect the module against electrostatic discharge, reverse polarity and voltage transients. |
Precision Resistors and Capacitors | Provide power filtering, pull-up resistance, signal filtering and stable circuit operation. |
Board-to-Board Connector | Carries power, ground, communication and interrupt signals between the module and the robot controller. |
PCB and Mounting Holes | Provide electrical connections and secure mechanical installation inside the robot. |
How the Gyroscope Works
A MEMS gyroscope contains a microscopic vibratingstructure. When the robot rotates, the Coriolis effect causes a smalldisplacement inside the sensing element. The sensor detects this displacementand converts it into an angular-velocity signal.
A three-axis gyroscope measures rotation around:
Roll: Rotation around the longitudinal axis
Pitch: Rotation around the lateral axis
Yaw: Rotation around the vertical axis
The robot controller integrates angular-velocity data overtime to estimate changes in orientation. Because integration can accumulatedrift, gyroscope data is often combined with accelerometer, magnetometer,encoder or vision data.
Main Functions
Three-axis angular-velocity measurement
Rotational-motion detection
Robot posture stabilization
Dynamic balance control
Joint movement monitoring
Direction-change detection
Vibration and abnormal-motion detection
Short-term orientation estimation
Multi-sensor data fusion
Axis Configurations
Configuration | Typical Use |
Single-Axis Gyroscope | Measures rotation around one defined axis, such as a wheel, turntable or robotic joint. |
Dual-Axis Gyroscope | Measures rotation around two axes in specialized motion-control systems. |
Three-Axis Gyroscope | Measures roll, pitch and yaw and is commonly used in mobile and dynamic robots. |
Communication Interfaces
Depending on the selected module design, the gyroscope cansupport:
I²C and SPI are commonly used for short board-levelconnections. CAN and RS-485 are more suitable for distributed robotic systems,longer cables and electrically noisy environments.
Recommended Specifications for the Product Page
Specification | Description |
Number of Axes | Single-axis, dual-axis or three-axis |
Full-Scale Range | Maximum measurable angular velocity, normally expressed in degrees per second |
Sensitivity | Output change corresponding to a specific angular velocity |
Resolution | Smallest detectable change in rotational speed |
Bias Stability | Stability of the zero-rate output over time |
Zero-Rate Output | Sensor output when no rotation is applied |
Noise Density | Noise level contained in the angular-velocity output |
Angular Random Walk | Long-term orientation error caused by integrated sensor noise |
Bandwidth | Range of rotational frequencies that can be measured |
Output Data Rate | Number of angular-velocity updates per second |
Cross-Axis Sensitivity | Response on one axis caused by rotation around another axis |
Temperature Drift | Change in bias or sensitivity across the operating-temperature range |
Interface | I²C, SPI, UART, CAN or RS-485 |
Supply Voltage | Required input voltage |
Power Consumption | Typical and maximum operating current |
Operating Temperature | Supported environmental temperature range |
Start-Up Time | Time required before stable data is available |
Dimensions | PCB length, width and height |
Calibration | Factory calibration or user-calibration options |
Installation Considerations
Mount the module firmly on a rigid part of the robot.
Align the gyroscope axes with the robot coordinate system.
Record the mounting orientation in the robot-control software.
Keep the module away from severe mechanical vibration and repeated impact.
Avoid flexible mounting structures that can introduce unwanted movement.
Keep sufficient distance from high-current motor cables and switching power circuits.
Use stable power, grounding and filtering to reduce electrical noise.
Perform zero-bias calibration after installation and before operation.
Allow the module to reach a stable temperature when high accuracy is required.
Combine gyroscope data with accelerometer, encoder or vision data to reduce accumulated orientation drift.
Important Technical Note
A gyroscope measures angular velocity, notabsolute position or absolute orientation. Orientation is calculated byintegrating angular velocity over time, which can produce accumulated drift.For long-term attitude estimation, the gyroscope should normally be combinedwith other sensors through a sensor-fusion algorithm.


